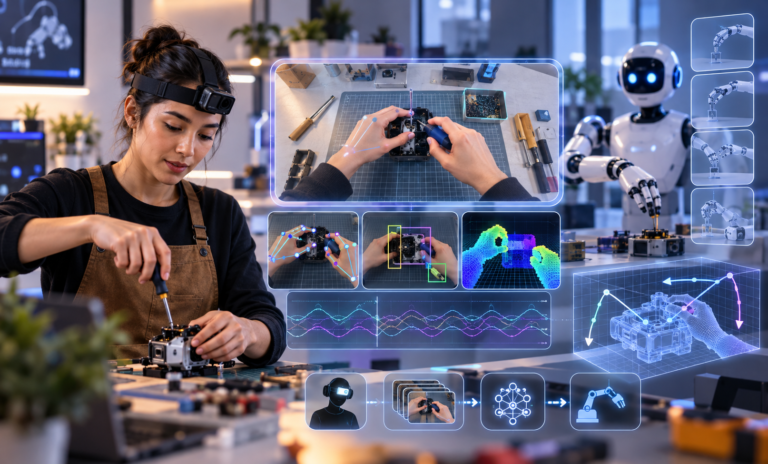
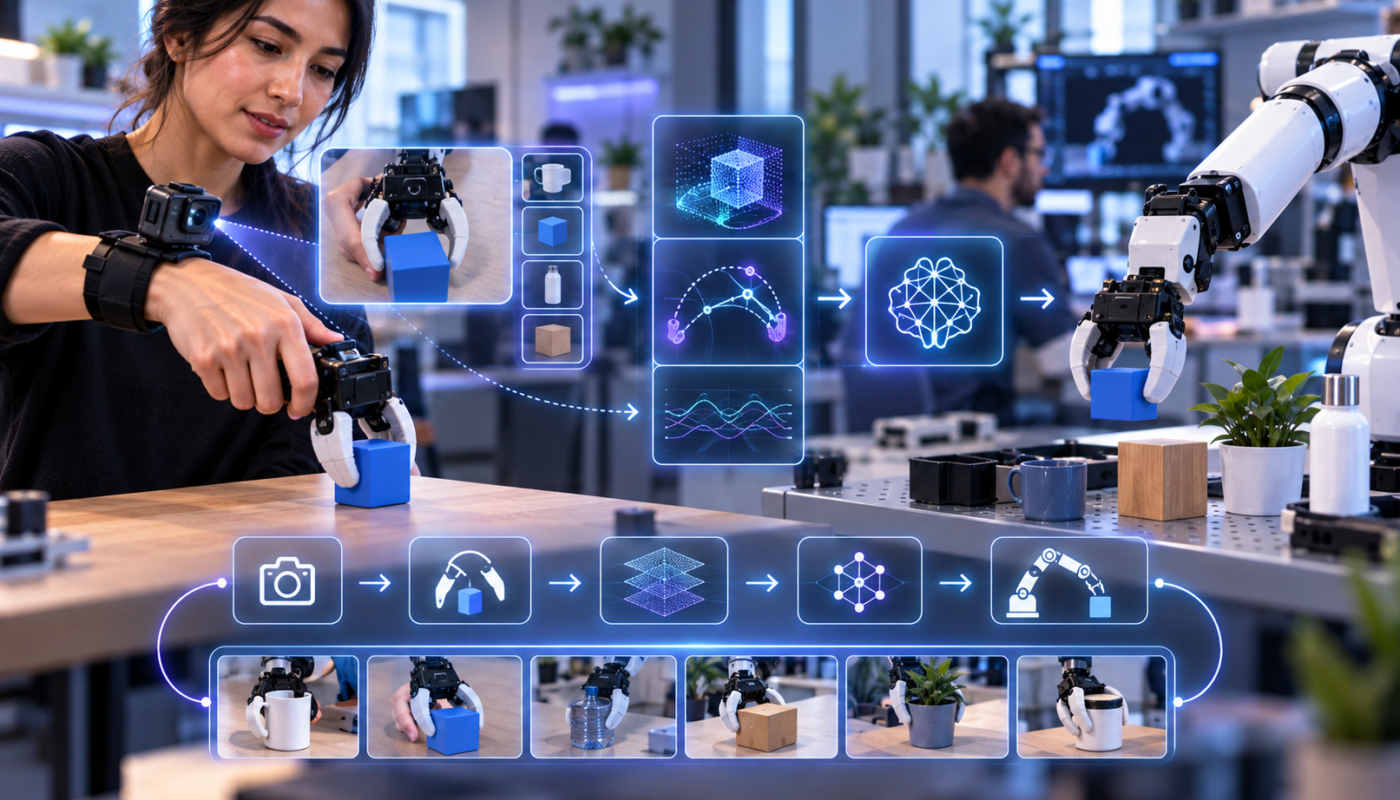
Most robot demonstration data has historically required a lab, a real robot arm, and an operator — which puts a hard ceiling on how much data anyone can collect.
What UMI changes
A handheld gripper rig with an onboard camera lets a person perform a grasping task in any real-world environment — a kitchen, a workshop — while recording exactly the sensor data a robot policy needs to learn from.
In-the-wild collection
Because the rig doesn’t require a fixed lab setup, contributors can capture grasp demonstrations across far more object types and environments than a stationary robot ever could.
Generalization
Policies trained on this kind of varied, in-the-wild demonstration data tend to generalize better to novel objects than policies trained purely on lab-collected data.